Mobile robotics is one of the fastest-growing areas of warehouse automation, but not every mobile robot does the same job. Shelf-to-person robots and autonomous mobile robots (AMRs) for horizontal transportation differ in how they navigate, where they operate and what they are designed to do. For many operations, the greatest value comes from using both.
The term “mobile robot” now covers a wide range of machines. Two applications in particular are becoming central to modern intralogistics strategies. Shelf-to-person robots store inventory and bring it to the picker. Transport AMRs keep pallets, containers and materials moving across the facility. For any operation weighing up mobile robotics, the right choice, or the right combination, depends on where flexibility is most needed in the material flow.
Bringing the goods to the operator
Shelf-to-person robots change the traditional picking model. Instead of operators walking the aisles to pick locations, robots retrieve storage racks and deliver them directly to ergonomically designed picking stations. This removes non-value-added travel, improves picking accuracy and creates a more comfortable working environment for staff.
The approach suits operations with broad, frequently changing SKU ranges and high-speed fulfilment requirements. It is also a strong fit for buildings where limited height or layout constraints rule out high-bay storage, which makes it a practical option for brownfield sites. The main requirement is a sufficiently large, level floor area for the robot grid.
Scalability is a further advantage. Storage capacity and throughput can be increased independently of each other: adding racks increases capacity, while adding robots increases throughput. Typical applications include omnichannel and e-commerce fulfilment, spare parts warehousing and any environment where a wide mix of products must be picked quickly and accurately. Swisslog’s CarryPick storage and picking system is built on this principle.
Keeping materials moving across the site
Shelf-to-person robots typically operate within a defined, fenced zone. Transport AMRs work in the open and dynamic environment of the wider warehouse. They localise themselves using laser-based natural navigation (SLAM), so no floor-installed guidance is required, and routes can be changed in software as layouts evolve. Certified safety laser scanners, often supplemented by 3D cameras, detect people and obstacles and slow down or stop the vehicle. This allows safe operation in mixed traffic alongside people and forklifts, in line with EN ISO 3691-4.
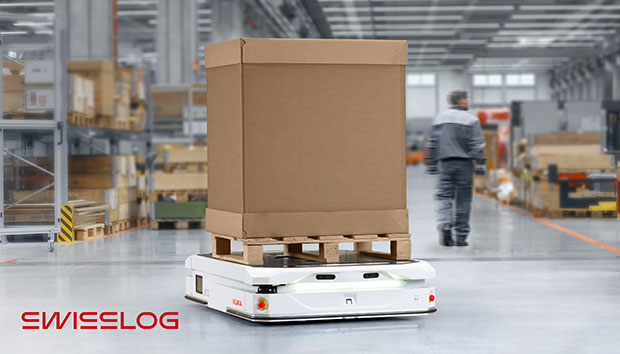
Transport AMRs move pallets, containers and materials between receiving, storage, production, buffer and shipping areas, with payload capacities typically reaching up to 3,000 kg. Common applications include production line supply, transport between warehouse zones, cross-docking, picking support and internal material circulation. They serve a wide range of sectors, including e-commerce, retail, 3PL, FMCG, food and beverage, electronics and pharmaceuticals.
The contrast with traditional AGVs is significant. Because transport AMRs rely on onboard sensors and digital maps rather than embedded wires or magnetic strips, they can usually be deployed quickly with limited disruption to existing operations. The fleet can then grow as transport demand increases, without changes to the wider infrastructure. Swisslog’s IntraMove AMRs are designed for this kind of point-to-point transport of medium to heavy loads.
Better together
The two technologies do not compete. Each addresses a different stage of the warehouse process, and the strongest results often come from combining them within a coordinated material flow.
In a combined system, AMRs move inbound pallets from receiving to storage buffers or dedicated replenishment workstations, where operators transfer the goods into the storage racks. Shelf-to-person robots then manage storage and deliver inventory to picking stations as orders are released. Once picking is complete, AMRs carry finished orders on to consolidation, packing or shipping.
The result is a continuous, largely automated process from inbound to shipping, with minimal manual handling at any stage and little or no investment in conveyors. Each technology handles the task it is designed for, and well-planned handover points keep goods flowing between them.
The software layer matters
Both systems depend on fleet management software, but their priorities differ considerably. Shelf-to-person software focuses on picking productivity, managing order waves, inventory positioning and workload balancing across pick stations. Transport AMR software prioritises movement efficiency, assigning jobs based on proximity, battery level and real-time traffic conditions.
Both fleets need to integrate cleanly with the warehouse management system (WMS) and warehouse execution system (WES), which orchestrate tasks across the operation. Open interfaces and standards such as VDA 5050 simplify this integration and keep the system flexible for future expansion. Getting the software layer right is just as important as choosing the hardware.
A sound basis for the decision
For companies introducing mobile robotics for the first time, or extending an existing automation footprint, understanding these distinctions is the foundation of a sound technology decision. In many cases the answer will be both, with each robot deployed where it adds the most value.
For a full technology comparison and application overview, download the Swisslog white paper on shelf-to-person robots and transport AMRs, at: www.swisslog.com/whitepapers
Comments are closed.